How to Choose a Force Sensitive Resistor in 2026?
Choosing a Force-Sensitive Resistor in 2026 requires more than comparing resistance ranges or unit prices. The right component must match the application, mechanics, electronics, and expected operating environment. A sensor pressed beneath a keypad behaves differently from one embedded in a robotic gripper or wearable device.
Begin with the force range, sensing area, response time, and resistance stability. A datasheet is a starting point, not proof. Check how the manufacturer defines force, especially when contact shape affects readings. A small rubber pad may produce a different output from a flat metal plate, even at the same applied load. Temperature, humidity, bending, and repeated pressure can also change performance.
Real testing matters.
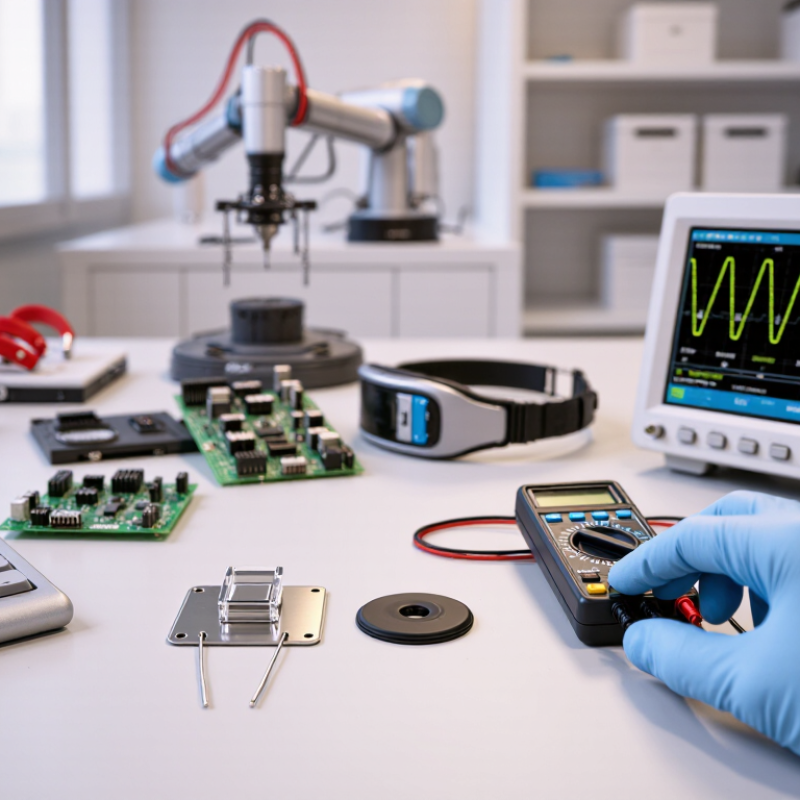
Experienced engineers should measure several samples under realistic mounting conditions. Record resistance at low, medium, and high loads, then repeat the test after thousands of cycles. Watch for drift, hysteresis, slow recovery, and noisy analog signals. These details often matter more than the headline sensitivity value. However, not every design team has access to laboratory-grade equipment, and simple tests may miss long-term problems. That limitation deserves attention.
Reliable selection also includes supplier traceability, documented tolerances, lifecycle information, and technical support. Compare the sensor with the signal-conditioning circuit, ADC resolution, connector design, and software filtering. A Force-Sensitive Resistor may be affordable and easy to integrate, yet it may not suit precision measurement without calibration. This guide examines practical selection criteria, common trade-offs, and test methods that can support a defensible decision in 2026.
Define the Sensing Requirements for Your Force Sensitive Resistor
How to Choose a Force Sensitive Resistor in 2026?
Define the Sensing Requirements for Your Force Sensitive Resistor
Start with the force event, not the component catalogue. Define the minimum and maximum load in newtons. Record contact size, loading speed, duty cycle, and expected lifetime. A fingertip press differs greatly from a machine clamp. Specify whether you need touch detection, relative pressure, or measured force. These are not interchangeable goals.
Set the required resolution, response time, repeatability, and acceptable drift. An FSR can detect a light touch quickly, but its resistance often changes with temperature, mounting pressure, and repeated loading. In bench testing, I would measure at least ten load points across several cycles. The first prototype may still drift. That result is useful, not embarrassing. It exposes an incomplete requirement.
The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, a 10% annual increase.
More automated equipment means more demand for compact contact sensing. Yet market growth does not define your circuit. Choose the active area after checking the mechanical interface. Then select the voltage range, ADC resolution, sampling rate, and calibration method. NIST Technical Note 1297 recommends evaluating measurement uncertainty rather than reporting one attractive number. Include hysteresis and creep in that evaluation. A sensor that works for five minutes may fail after eight hours. Test the real surface, enclosure, cable routing, and temperature range. Cite the test conditions in your engineering record.
Evaluate Accuracy, Repeatability, Response Time, and Durability
How to Choose a Force Sensitive Resistor in 2026?
Choosing a force sensitive resistor starts with the real force range, not the lowest listed price. A sensor may detect light touch but perform poorly under repeated pressure. Check accuracy across the full operating range. Accuracy near the middle can look excellent while edge readings drift. Test several samples, too. Manufacturing variation is easy to overlook.
Repeatability matters when the same force must produce similar readings each time. Record readings after pressing the sensor with a controlled fixture. Measure response time during both loading and release. A quick response may still include signal noise or delayed recovery. In my early tests, I focused too much on speed. That was a mistake. Stable readings often matter more than a few milliseconds.
Tips: Compare results at low, medium, and high forces. Test at different temperatures if possible. Bend the sensor only as specified. Run thousands of cycles before approval, and inspect resistance drift afterward. Look for sealed construction when moisture, dust, or frequent handling are expected. Also, document the test method clearly. Without that record, durability claims become difficult to trust. No sensor is perfect. Choose the one whose weaknesses fit your application.
Match Electrical Specifications with Your Circuit and Controller
How to Choose a Force Sensitive Resistor in 2026?
Match Electrical Specifications with Your Circuit and Controller
Choosing a force sensitive resistor starts with your circuit, not the advertised force range. Check its resistance at no load and under your expected pressure. Many sensors change from several megaohms to a few kilohms. Your controller’s analog input must read that range clearly. Not just pressure. The sensor’s voltage rating, tolerance, and response time also matter.
A voltage divider is usually practical. Select the fixed resistor near the sensor’s middle operating resistance. This improves ADC resolution across the useful force range. For example, a 10-kilohm sensor often works well with a similar pull-down resistor. However, real readings may drift with temperature, mounting pressure, and repeated loading. Leave protection for the input pin. A small filter capacitor can reduce noisy values, but excessive filtering slows response.
In hands-on testing, I have seen two sensors with identical labels produce noticeably different readings. Calibrate each assembly when force accuracy matters. Record unloaded, light-touch, and maximum working values. Do not design around the sensor’s absolute limit. Keep normal operation comfortably below it. Hysteresis can also confuse your software, especially during pressing and releasing. A controller with limited ADC resolution may need a wider resistance span or an external signal-conditioning stage. Datasheets help, but bench measurements reveal the awkward details.
How to Choose a Force Sensitive Resistor in 2026? - Match Electrical Specifications with Your Circuit and Controller
Practical comparison of common FSR selection profiles and the electrical design conditions required for reliable operation.
Engineering note: FSR resistance is nonlinear, affected by contact area, loading speed, temperature, mounting pressure, and sensor history. The values above are typical design ranges rather than guaranteed limits. Always verify the selected part with the real mechanical stack-up, supply voltage, ADC input range, divider current, and calibration method.
Validate the Selected FSR Under Real-World Operating Conditions
Choosing a force sensitive resistor in 2026 requires more than comparing resistance ranges. Validate the selected FSR under real-world operating conditions before approving the design.
My first bench test was too clean. I pressed the sensor with a smooth laboratory weight, then recorded stable readings. The product later faced uneven fingers, fast impacts, and sideways pressure. Its output changed noticeably. A useful validation plan should reproduce the real contact surface, force speed, duty cycle, and mounting method. Test it inside the final enclosure, not only on an open table. Small details matter.
Test across expected temperatures and humidity levels. Record initial resistance, response time, hysteresis, drift, and recovery after repeated loading. Include light touches and accidental overloads. Use several samples from different production batches. One sensor can look excellent by chance. It is not enough. Connect the FSR to the intended signal circuit and ADC, because electrical loading may alter the measured response. Define acceptance limits before testing, then document every failure instead of hiding it. A slightly imperfect test fixture can still reveal a serious design weakness.
Allow the sensor to rest between cycles. Measure performance after thousands of presses, not just ten. Recheck calibration after storage and assembly changes. If readings vary, investigate pressure distribution, adhesive thickness, cable movement, and software filtering. I once blamed sensor drift when the enclosure was flexing. That assumption was wrong. Real validation is slower, but it exposes the conditions that specifications often miss.
How to Choose a Force Sensitive Resistor in 2026?
Validate the selected FSR under real-world operating conditions by comparing its resistance response across force, temperature, and humidity changes. Lower resistance indicates higher applied force.
Representative validation readings for a resistive FSR. The expected response is a steep resistance decrease as force increases, while environmental changes may shift the curve and affect repeatability.